本文实例为大家分享了OpenCV实现相机校正的具体代码,供大家参考,具体内容如下
1. 相机标定
根据张正友校正算法,利用棋盘格数据校正对车载相机进行校正,计算其内参矩阵,外参矩阵和畸变系数。
标定的流程是:
2.关于相机校正用到的几个API:
1、寻找棋盘图中的棋盘角点
rect, corners = cv2.findChessboardCorners(image, pattern_size, flags)
参数:
CV_CALIB_CB_ADAPTIVE_THRESH :使用自适应阈值(通过平均图像亮度计算得到)将图像转换为黑白图,而不是一个固定的阈值。
CV_CALIB_CB_NORMALIZE_IMAGE :在利用固定阈值或者自适应的阈值进行二值化之前,先使用cvNormalizeHist来均衡化图像亮度。
CV_CALIB_CB_FILTER_QUADS :使用其他的准则(如轮廓面积,周长,方形形状)来去除在轮廓检测阶段检测到的错误方块。
返回:
2、检测完角点之后可以将测到的角点绘制在图像上,使用的API是:
cv2.drawChessboardCorners(img, pattern_size, corners, rect)
参数:
注意:如果发现了所有的角点,那么角点将用不同颜色绘制(每行使用单独的颜色绘制),并且把角点以一定顺序用线连接起来。
3、利用定标的结果计算内外参数
ret, mtx, dist, rvecs, tvecs = cv2.calibrateCamera(object_points, image_points, image_size, None, None)
参数:
返回:
2.1 图像去畸变
上一步中得到相机的内参及畸变系数,利用其进行图像的去畸变,最直接的方法就是调用opencv中的函数得到去畸变的图像:
def img_undistort(img, mtx, dist):
 dst = cv2.undistort(img, mtx, dist, None, mtx)
 return dst
求畸变的API:
dst = cv2.undistort(img, mtx, dist, None, mtx)
参数:
返回:
3. 相机校正
import cv2
import numpy as np
import matplotlib.pyplot as plt
import matplotlib.image as mpimg
import glob
def plot_contrast_imgs(origin_img, converted_img, origin_img_title="origin_img", converted_img_title="converted_img", converted_img_gray=False):
 """
 用于对比显示两幅图像
 """
 fig, (ax1, ax2) = plt.subplots(1, 2, figsize=(15, 20))
 ax1.set_title(origin_img_title)
 ax1.imshow(origin_img)
 ax2.set_title(converted_img_title)
 if converted_img_gray==True:
  ax2.imshow(converted_img, cmap="gray")
 else:
  ax2.imshow(converted_img)
 plt.show()
# 1. 参数设定:定义棋盘横向和纵向的角点个数并指定校正图像的位置
nx = 9
ny = 6
file_paths = glob.glob("./camera_cal/calibration*.jpg")
# 2. 计算相机的内外参数及畸变系数
def cal_calibrate_params(file_paths):
 object_points = []  # 三维空间中的点:3D
 image_points = []# 图像空间中的点:2d
 # 2.1 生成真实的交点坐标:类似(0,0,0), (1,0,0), (2,0,0) ....,(6,5,0)的三维点
 objp = np.zeros((nx * ny, 3), np.float32)
 objp[:, :2] = np.mgrid[0:nx, 0:ny].T.reshape(-1, 2)
 # 2.2 检测每幅图像角点坐标
 for file_path in file_paths:
  img = cv2.imread(file_path)
  # 将图像转换为灰度图
  gray = cv2.cvtColor(img, cv2.COLOR_BGR2GRAY)
  # 自动检测棋盘格内4个棋盘格的角点(2白2黑的交点)
  rect, corners = cv2.findChessboardCorners(gray, (nx, ny), None)
  # 若检测到角点,则将其存储到object_points和image_points
  if rect == True:
object_points.append(objp)
image_points.append(corners)
 # 2.3 获取相机参数
 ret, mtx, dist, rvecs, tvecs = cv2.calibrateCamera(object_points, image_points, gray.shape[::-1], None, None)
 return ret, mtx, dist, rvecs, tvecs
def img_undistort(img, mtx, dist):
 """
 图像去畸变
 """
 return cv2.undistort(img, mtx, dist, None, mtx)
# 测试去畸变函数的效果
file_paths = glob.glob("./camera_cal/calibration*.jpg")
ret, mtx, dist, rvecs, tvecs = cal_calibrate_params(file_paths)
if mtx.any() != None:  # a.any() or a.all()
 img = mpimg.imread("./camera_cal/calibration1.jpg")
 undistort_img = img_undistort(img, mtx, dist)
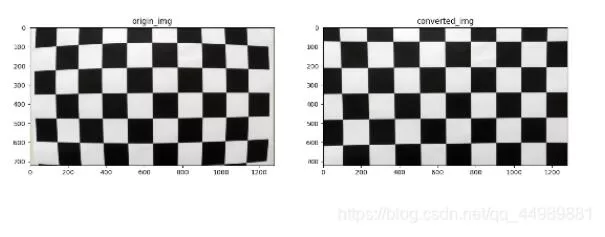
 plot_contrast_imgs(img, undistort_img)
 print("done!")
else:
 print("failed")
执行代码: